New Direct-Drive Robotic Hands Bring 13-DOF Manipulation and Modular Maintenance to IROS 2026
DH-Robotics showcases its lightweight ADH-5-13 and high-force UDH-3-7 end effectors, engineered for rapid sensor swaps and seamless ROS 2, Isaac, and MuJoCo integration.
Published November 12, 2026
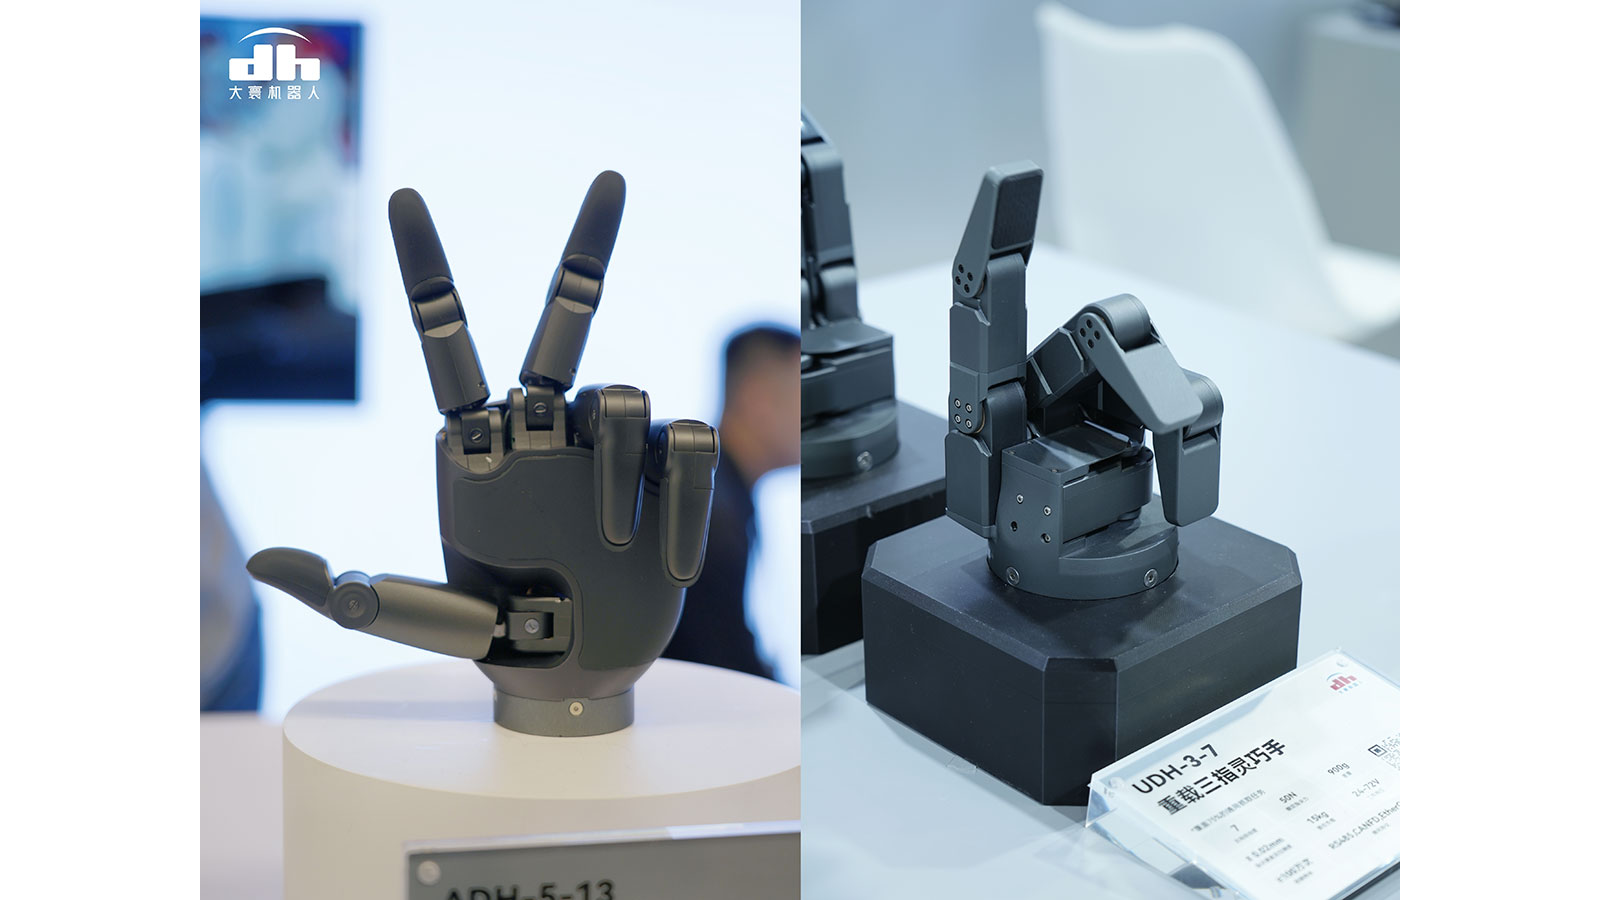
Debuted at IROS 2026, DH-Robotics’ direct-drive dexterous hand lineup includes the 13-DOF, five-finger ADH-5-13 (with a 20 kg payload) and the 7-DOF, three-finger UDH-3-7 (with a 15 kg payload).
DH-Robotics debuted the ADH-5-13, a five-finger dexterous hand with 13 independently controllable active degrees of freedom (DOF), at IROS 2026 in Pittsburgh. The company also demonstrated the UDH-3-7, its three-finger direct-drive dexterous hand, alongside a portfolio of two-, three- and five-finger end effectors for a range of gripping and manipulation tasks.
The debut reflects DH-Robotics' "Dexterity as Productivity" approach: matching hand architecture, sensing and control to the manipulation requirements of embodied AI research, teleoperation and robotic systems.
ADH-5-13: a five-finger platform for multi-finger manipulation
The ADH-5-13 uses an anthropomorphic five-finger configuration with 13 active DOF. The thumb, index finger and middle finger each have three DOF; the ring and little fingers each have two. The index and middle fingers also provide ±15° of lateral motion for a broader range of multi-finger poses.
At 735 g, the hand is designed to balance dexterity with system weight. DH-Robotics specifies a maximum lifting payload of up to 20 kg once an object is grasped.
The ADH-5-13 integrates fingertip tactile sensing and can accommodate additional sensing options, including electronic skin, six-axis force/torque sensors and vision-based tactile sensors. Sensors and individual modules can be replaced without dismantling the entire hand or a full finger, simplifying service and maintenance. According to DH-Robotics, this serviceable design improves maintenance efficiency by 300%, helping reduce downtime and operating and maintenance costs.
The hand's fully direct-drive, backdrivable architecture provides independent control of all 13 active DOF. Dual magnetic encoders at each joint provide position feedback, and DH-Robotics specifies fingertip positioning repeatability of ±0.2 mm. The company says the architecture supports hybrid force/position control and compliant contact behavior in manipulation tasks.
UDH-3-7: strength, flexibility and a compact three-finger form factor
The UDH-3-7 is built around a streamlined three-finger configuration with seven active DOF. DH-Robotics specifies a maximum payload of 15 kg, maximum fingertip force of 50 N, positioning repeatability of ±0.02 mm and a design life of one million cycles.
The hand also uses a direct-drive, backdrivable design. Its thumb supports a 180° range of rotation and opposition, enabling different grasp configurations for objects with varied shapes and materials.
UDH-3-7 supports CAN FD, RS-485 and EtherCAT. Development tools support C++ and Python, while ROS 2 integration and workflows using Isaac and MuJoCo can help teams evaluate and integrate the hand in embodied AI systems.
A portfolio organized around the task
DH-Robotics positions its two-, three- and five-finger end effectors around distinct manipulation needs:
- Two-finger end effectors: general-purpose gripping and grasping.
- Three-finger dexterous hands: a balance of strength, dexterity and working space for manipulation.
- Five-finger dexterous hands: coordinated multi-finger manipulation and more complex dexterous tasks.